Humanoid & legged robot joints
Backdrivable quasi-direct-drive joint modules, the kind used in quadrupeds, bipeds and humanoids: low gear ratios, high peak torque and fast CAN or EtherCAT control.
- Look for ratios around 6:1 to 10:1 for backdrivability.
- Hips and knees usually need the highest peak torque; ankles and arms less.
- Match every joint's bus voltage and protocol to one controller.
-

Steadywin GWK6010-8 Planetary Joint Motor
rated 5.68 N·mpeak 16.89 N·m8:1$95.90 -

Steadywin WGG6010-8 Exoskeleton Motor
rated 5.68 N·mpeak 16.89 N·m8:1$118.90 -

Steadywin WGG7010-8 Exoskeleton Motor
rated 7.6 N·mpeak 23.24 N·m8:1$122.90 -
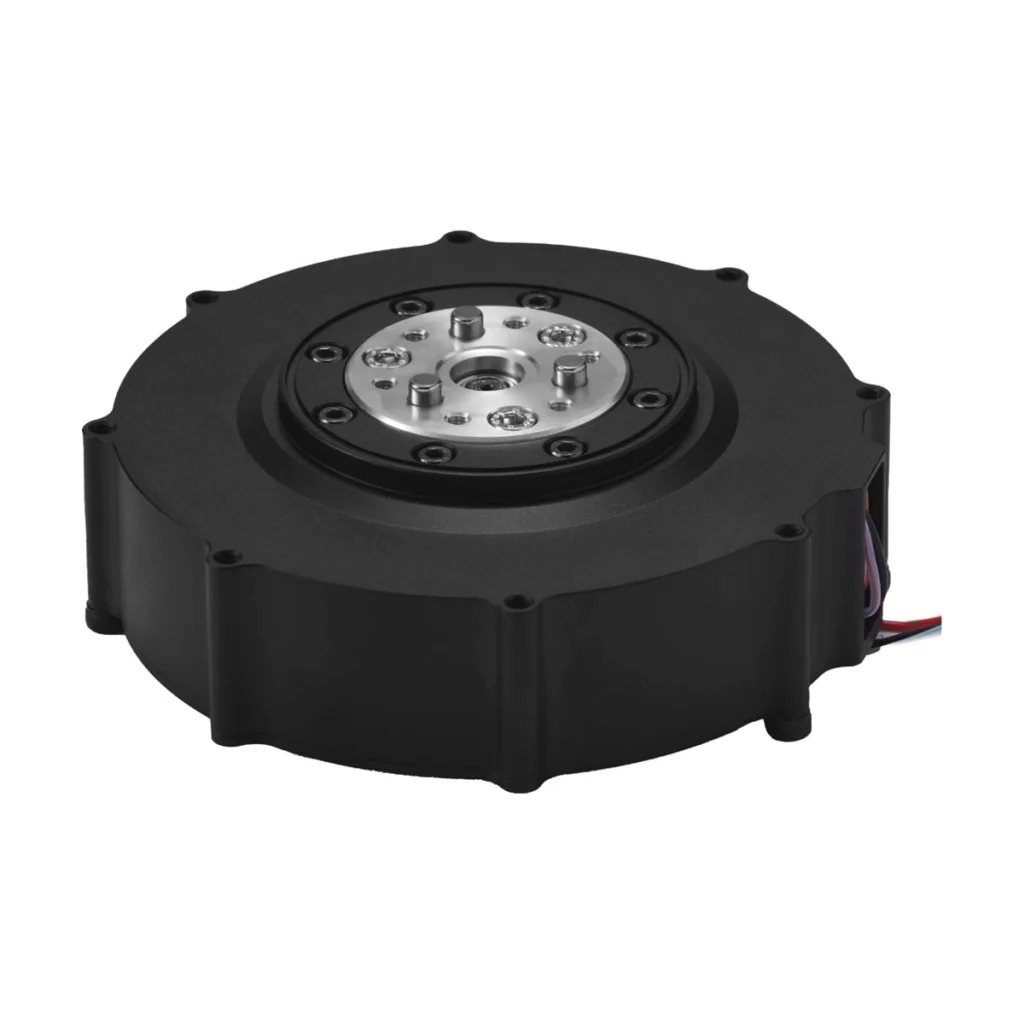
Steadywin GWK8108-8 Planetary Joint Motor
rated 10.2 N·mpeak 24.78 N·m8:1$127.90 -

Steadywin GIM4315-8 Planetary Joint Motor
rated 1.6 N·mpeak 14.25 N·m8:1$128.90 -
Steadywin GIM6010-8 Planetary Joint Motor
rated 5 N·mpeak 11 N·m8:1$128.90 -

Steadywin WGG7015-8 Exoskeleton Motor
rated 11.4 N·mpeak 31.71 N·m8:1$128.90 -

Steadywin WGG6013-9 Exoskeleton Motor
rated 9.8 N·mpeak 30.83 N·m9:1$131.90 -

Steadywin GIM3510-8 Planetary Joint Motor
rated 1 N·mpeak 6.28 N·m8:1$136.90 -

Steadywin GIM4310-10 Planetary Joint Motor
rated 1.63 N·mpeak 7.98 N·m10:1$143.90 -

Steadywin WGG8108-8 Exoskeleton Motor
rated 10.2 N·mpeak 24.78 N·m8:1$156.90 -

CubeMars AK45-10 Joint Actuator
rated 2.5 N·mpeak 7 N·m10:1$158.90 -
Steadywin GIM8108-8 Planetary Joint Motor
rated 7.5 N·mpeak 22 N·m8:1$160.90 -

Steadywin GIM6010-6 Planetary Joint Motor
rated 3.3 N·mpeak 8 N·m6:1$174.90 -

Steadywin TT4510-10 Joint Motor
rated 2.9 N·mpeak 11.95 N·m10:1$175.90 -
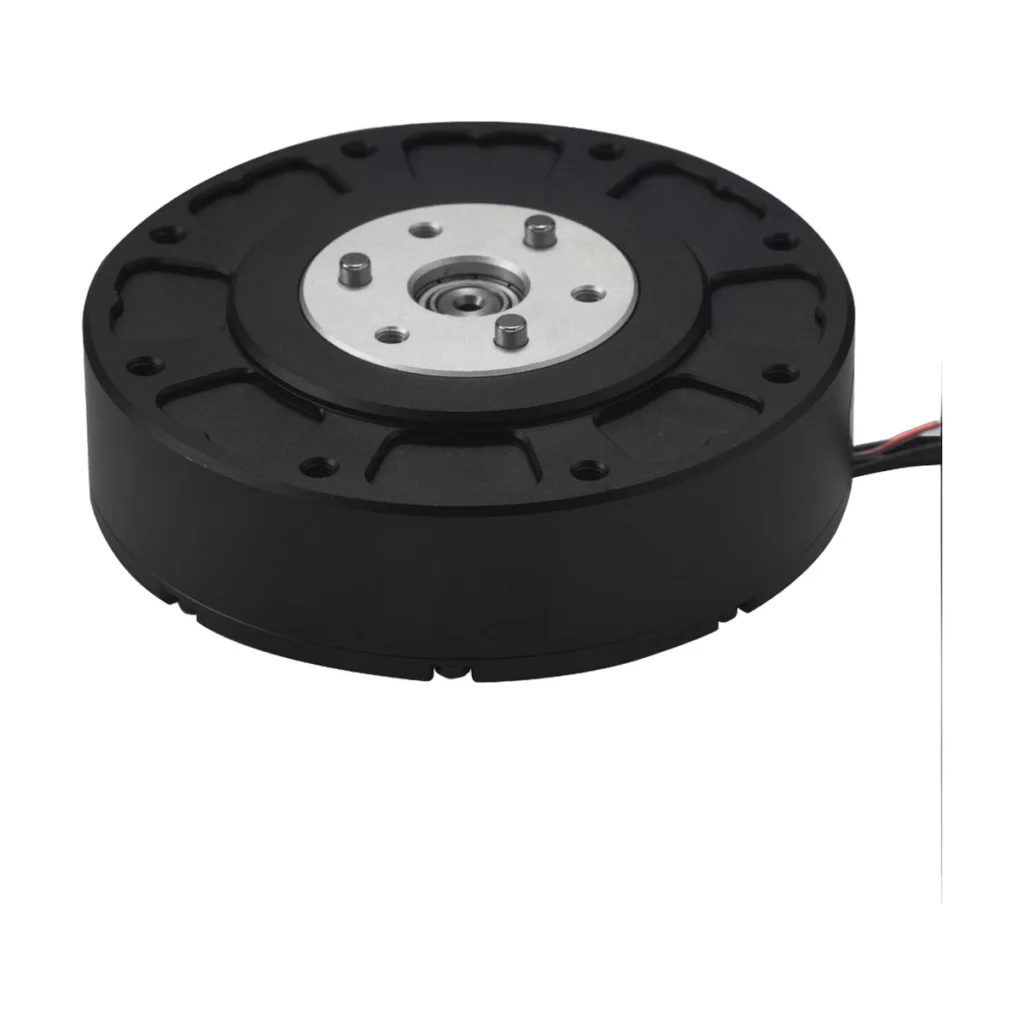
Steadywin GIM8108-6 Planetary Joint Motor
rated 5.46 N·mpeak 18.25 N·m6:1$199.90 -
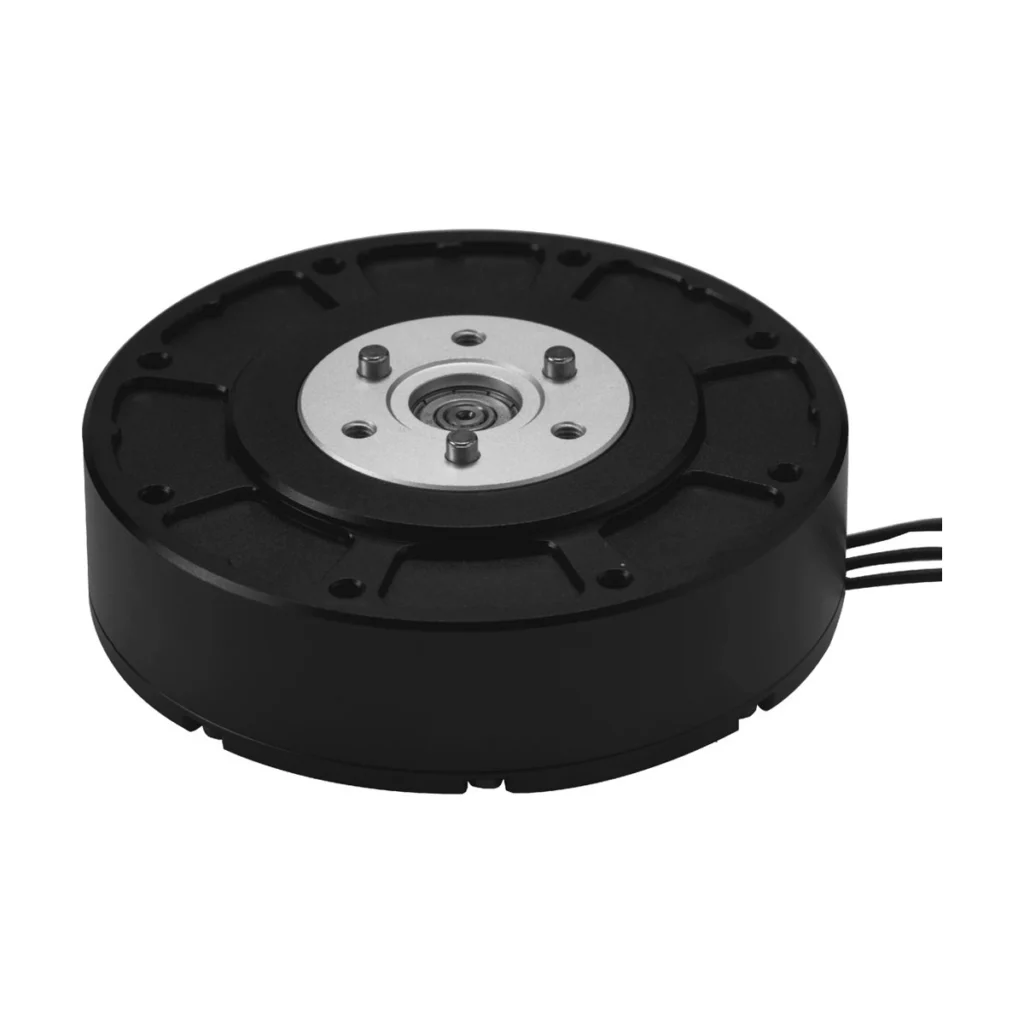
Steadywin GIM8108-9 Planetary Joint Motor
rated 8.19 N·mpeak 27.38 N·m9:1$199.90 -

CubeMars AKE60-8 Joint Actuator
rated 5 N·mpeak 12.5 N·m8:1$221.90 -

CubeMars AK60-6 Joint Actuator (V3.0 KV80)
rated 3 N·mpeak 9 N·m6:1$233.90 -

Steadywin GIM8115-6 Planetary Joint Motor
rated 7.6 N·mpeak 22 N·m6:1$236.90 -
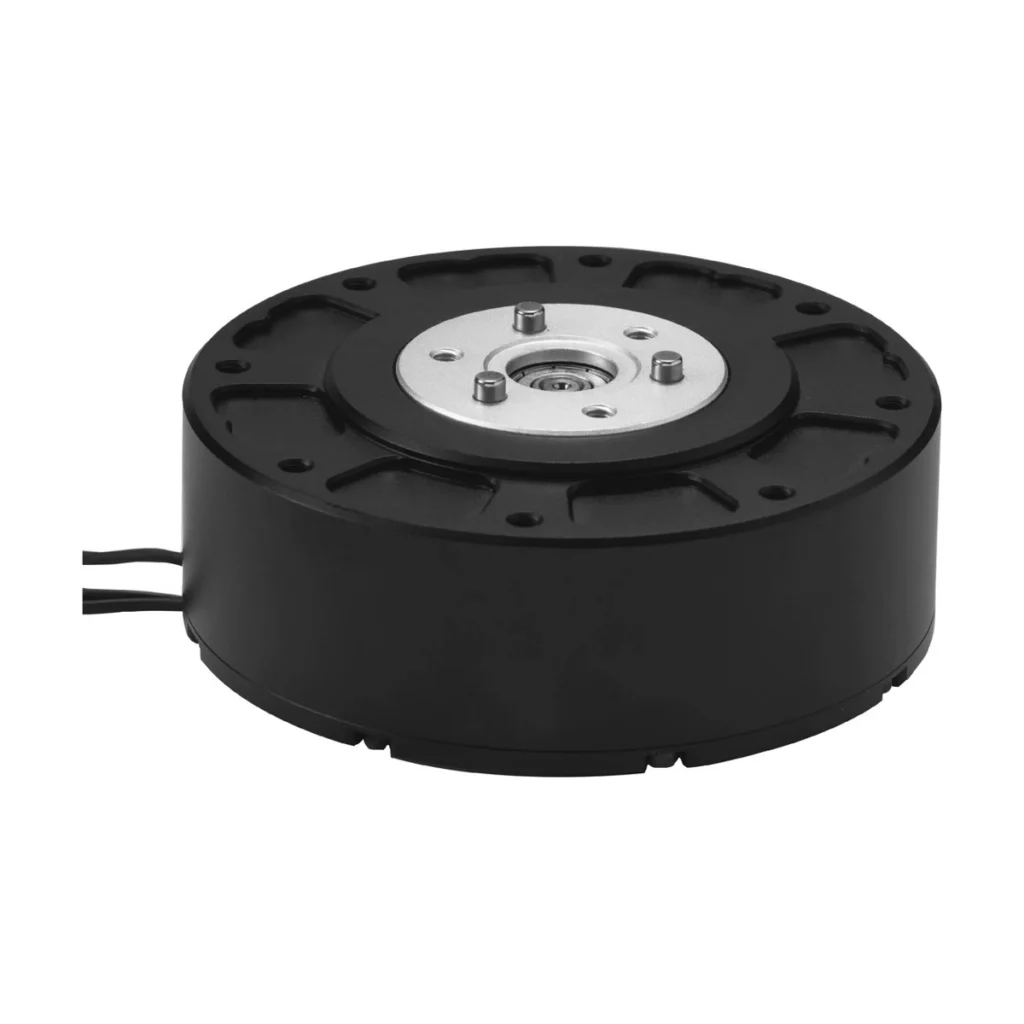
Steadywin GIM8115-9 Planetary Joint Motor
rated 13 N·mpeak 40 N·m9:1$236.90 -
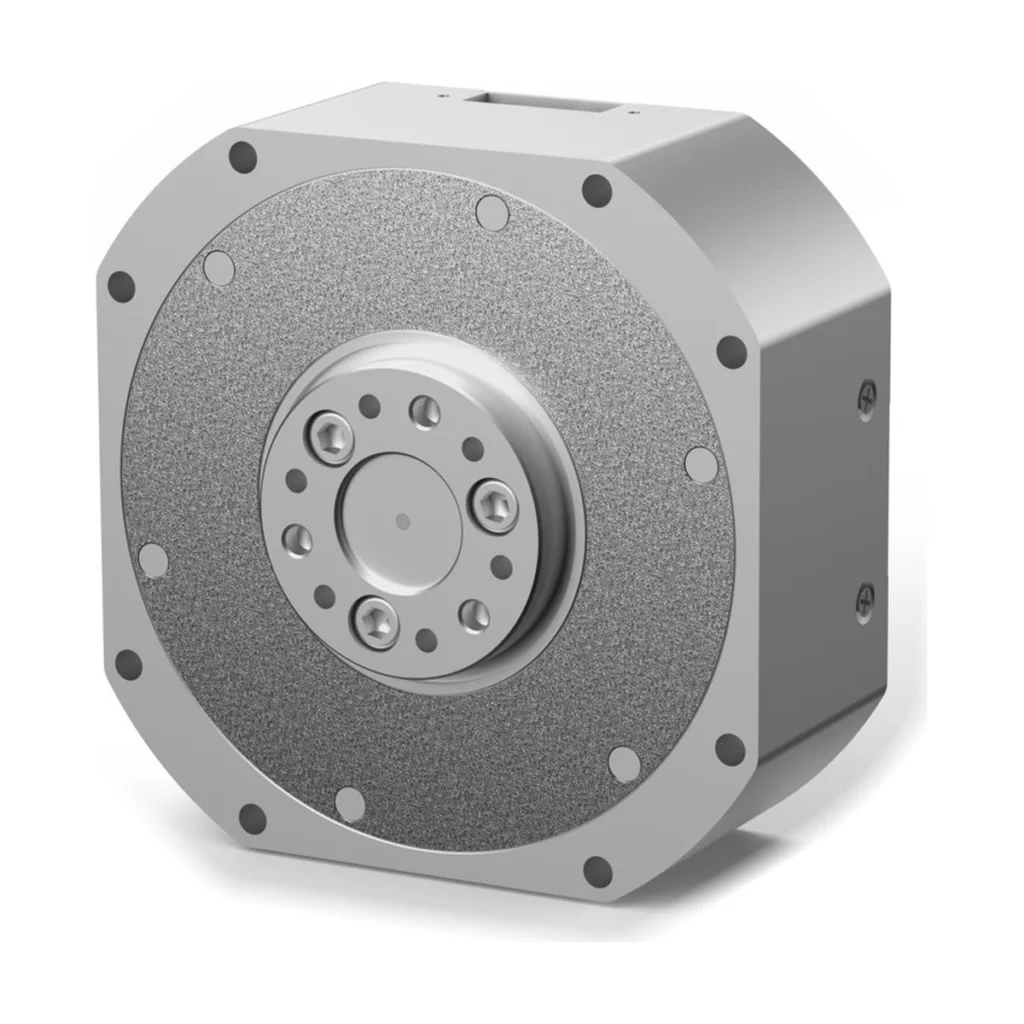
HighTorque HTPW-7507-02-DNE Planetary Joint Module Joint Actuator
rated 4 N·mpeak 12 N·m7:1$293.90 -
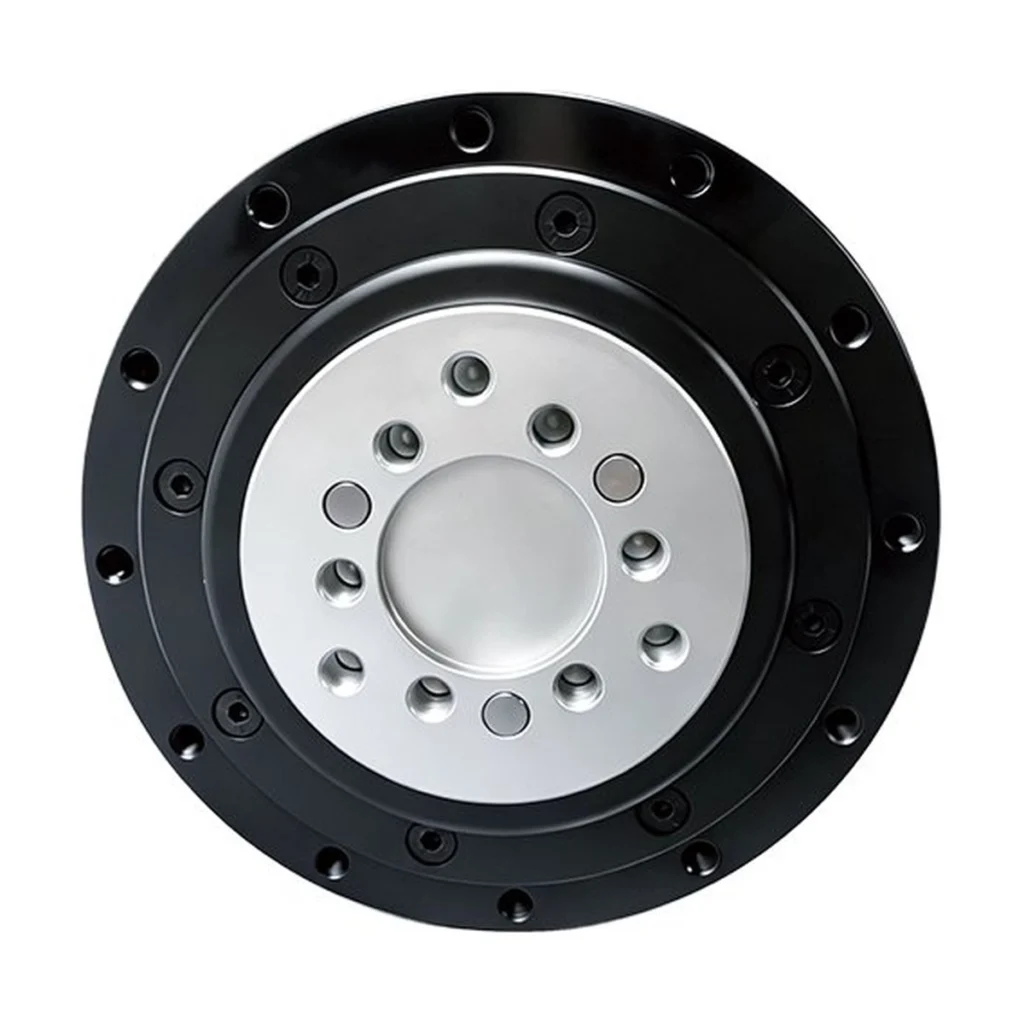
Steadywin TT8116-9 Joint Motor
rated 13 N·mpeak 60.07 N·m9:1$293.90 -
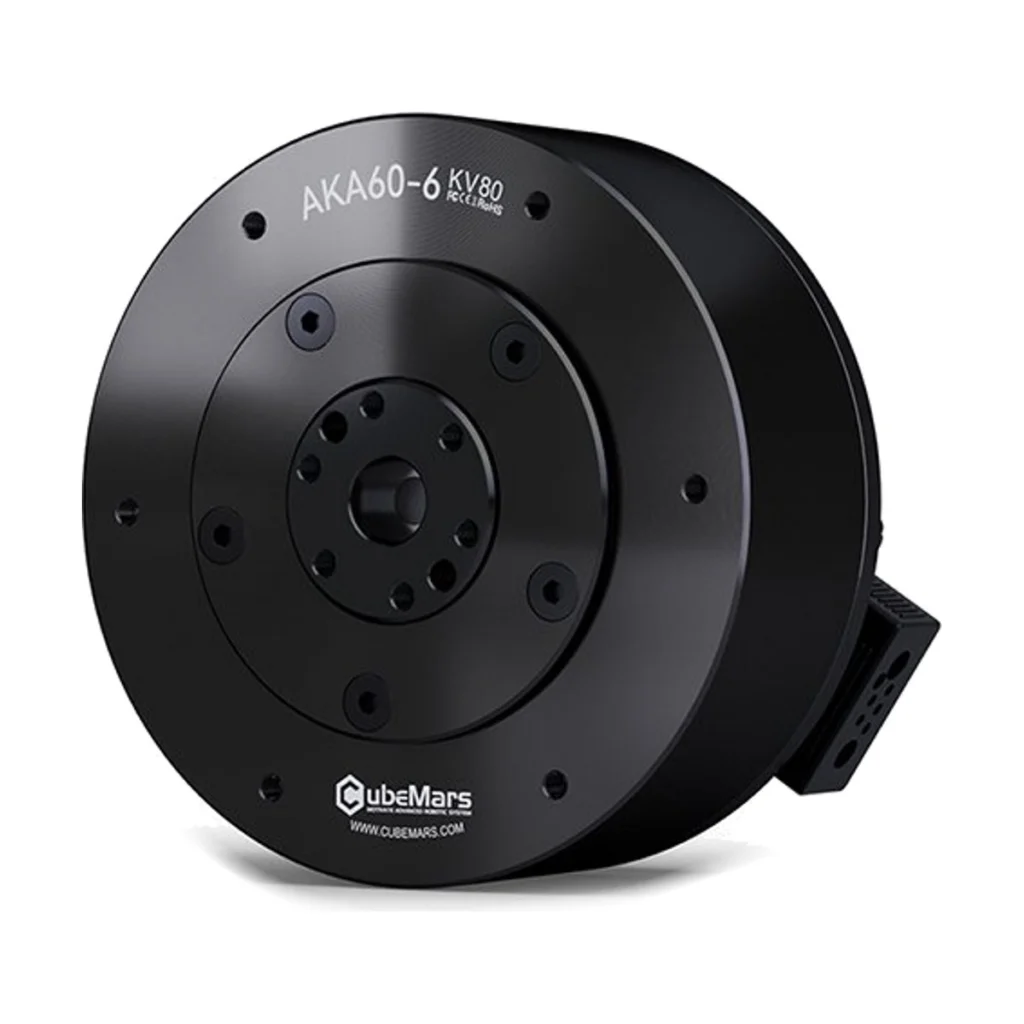
CubeMars AKA60-6 Joint Actuator
rated 3 N·mpeak 9 N·m6:1$303.90
Can’t find it here? Send a request.
The store lists what our manufacturers publish. For anything else, a different spec, a quantity price or a part we don’t carry yet, tell us what you need and we’ll find it.
- Parts and materials sourced from qualified manufacturers
- A landed quote: parts, freight, duties and tariffs
- Attach a BOM, drawing or spec sheet