Free shipping on every order. No tariffs or duties to pay at checkout or on delivery.

Steadywin·GIM3505-9·RJT-059

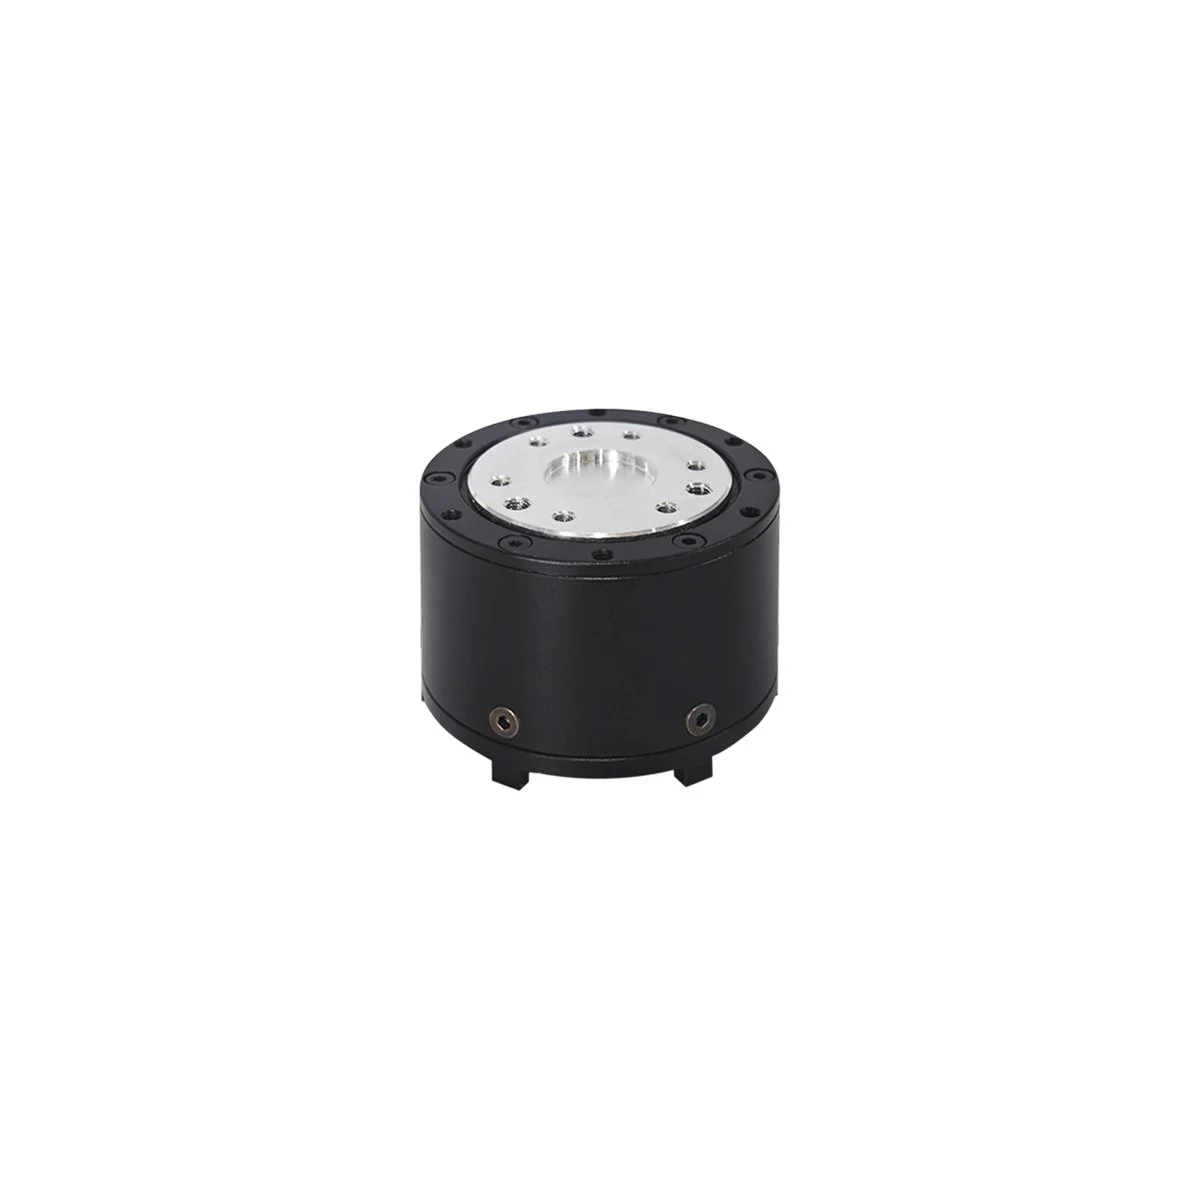
Steadywin GIM3505-9 Planetary Joint Motor

Price on request
No public list price. Tell us the quantity and we reply with a confirmed price, lead time and freight.

The Steadywin GIM3505-9 is a small planetary-geared BLDC joint actuator, 9:1 reduction, rated 0.71 N·m / stall 1.95 N·m at 24 V (12-40 V range), 258 rpm rated output speed, 38 W.

Shipping
Free on every order
Duties and tariffs
In the price, nothing extra at checkout
Minimum order
1 unit
In the box
Motor, gearing and driver included
Request a quoteNeed volume pricing or a custom configuration? Tell us what you need →
  • Free shipping On every order.
  • No tariffs at checkout Duties are in the price. Nothing to pay on delivery.
  • US seller of record US invoices, terms and support.
  • Maker's warranty Typically 12 months. Unused items can be returned within 30 days.
0.71 N·m
Torque (rated)
1.95 N·m
Torque (peak / max)
9:1
Gear ratio
CAN, RS485
Communication

Specifications

Performance

Torque (peak / max)
1.95 N·m
Torque (rated)
0.71 N·m
Output speed
258 rpm
Motion
Continuous rotary

Mechanical

Gear ratio
9:1
Weight
0.12 kg
Dimensions
Ø45 x 32.3 mm

Electrical

Supply voltage
24 V
KV
15.83 rpm/V

Interface

Encoder
14-bit on driver; second encoder supported
Communication
CAN, RS485

Specifications and photos are the maker's published data. Datasheets are available on request.

Typical applications

  • Legged and humanoid robots
  • Robot arms and cobots
  • Exoskeletons
  • Research and education platforms

Choosing the right one

  • Use peak torque for dynamic moves and rated torque for sustained load; keep continuous load under the rated value.
  • Low ratios (about 6:1 to 10:1, quasi-direct drive) are backdrivable and suit legged robots; high ratios (30:1 and up) suit arms that need stiffness.
  • Check bus voltage (24 V or 48 V) and communication (CAN or CAN FD, EtherCAT, RS485) against your controller.
  • A dual encoder reports absolute output position at power-up, so the joint needs no homing.
  • Compare torque density (N·m per kg) when weight matters.

Related guides

About this product

CAN and RS485 control, 14-bit encoder on the driver and support for a second output encoder; IP54 motor, 120 g without driver.

  • Series: GIM planetary joint motor

Similar torque

Closest matches in this category, from any supplier.

More from Steadywin

Visit storefront →