It carries an NVIDIA Jetson Orin NX compute module and an Intel RealSense camera. HighTorque sells it by quotation only.
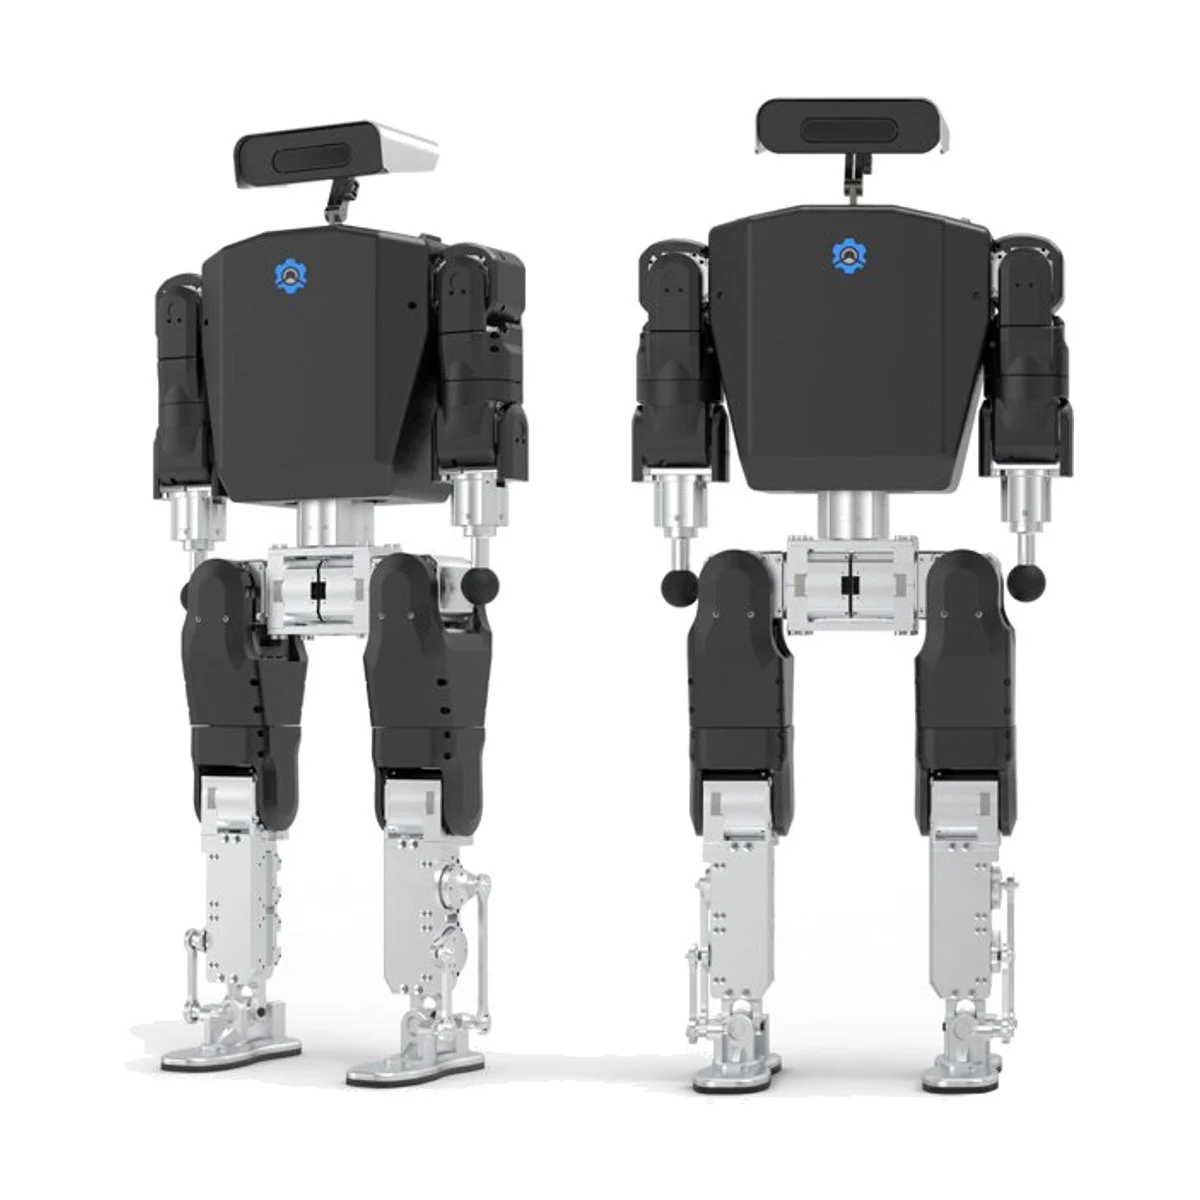
HighTorque Mini Hi Humanoid Robot
Price on request
No public list price. Tell us the quantity and we reply with a confirmed price, lead time and freight.
Financing available Pay later on net terms, or monthly over 12 to 60 months.See options →
23-DoF humanoid robot, 810 mm tall and 21.5 kg with battery, running on 48 V with three types of HighTorque joint modules on CAN-FD.
- Shipping
- Free on every order
- Duties and tariffs
- In the price, nothing extra at checkout
- Minimum order
- 1 unit
Part of the HighTorque Mini Pi and Mini Hi: compare all 5 models →
Request a quoteNeed volume pricing or a custom configuration? Tell us what you need →- Free shipping On every order.
- No tariffs at checkout Duties are in the price. Nothing to pay on delivery.
- US seller of record US invoices, terms and support.
- Maker's warranty Typically 12 months. Unused items can be returned within 30 days.
23
Active degrees of freedom
810 mm
Height
21.5 kg
Weight
NVIDIA Jetson Orin NX
Onboard computer
Specifications
Performance
- Payload
- 20 kg
- Active degrees of freedom
- 23
- Height
- 810 mm
Mechanical
- Weight
- 21.5 kg
Electrical
- Supply voltage
- 48 V
- Battery
- 43.2 V, 4500 mAh Li-ion
Interface
- Communication
- CAN FD (joints)
Integration
- Onboard computer
- NVIDIA Jetson Orin NX
- Sensors
- RealSense depth camera
- SDK and interfaces
- Open-source controller on GitHub
Specifications and photos are the maker's published data. Datasheets are available on request.
Made by
HighTorque Robotics
Typical applications
- Locomotion and reinforcement learning research
- Sim-to-real experiments
- University teaching and robotics courses
- Robot competitions and demonstrations
Choosing the right one
- Count the degrees of freedom you need: legs alone for locomotion research, arms and a waist for manipulation.
- Check the onboard computer against the models you will run on the robot; heavier policies need a GPU module.
- Check the simulator support (Isaac Gym, MuJoCo, Gazebo) and the open-source code before you buy; that is where most of the work happens.
- Plan for batteries and spare joints: runtime per charge is short, and falls are part of legged research.
Related guides
About this product
More from HighTorque Robotics
-

HighTorque HTDW-4438-30-NE Planetary Joint Module Joint Actuator
rated 2 N·mpeak 10 N·m30:1$291.90 -

HighTorque HTDW-5022-02-DNE Planetary Joint Module Joint Actuator
rated 3.5 N·mpeak 13 N·m22:1$291.90 -

HighTorque HTDW-5036-02-DNE Planetary Joint Module Joint Actuator
rated 6 N·mpeak 21 N·m36:1$291.90 -
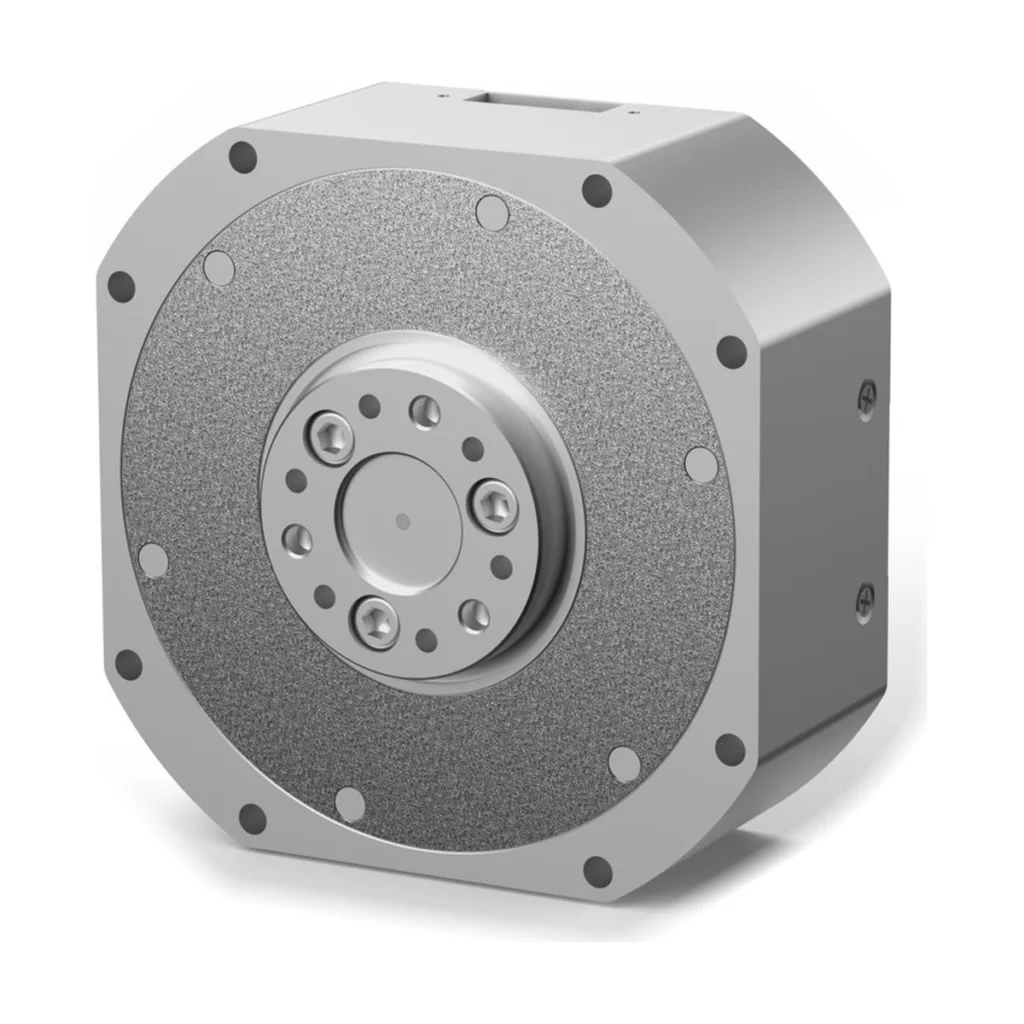
HighTorque HTPW-7507-02-DNE Planetary Joint Module Joint Actuator
rated 4 N·mpeak 12 N·m7:1$293.90