Controlled over CAN 2.0 or CANopen in speed, torque, position or MIT mode. For humanoids, quadrupeds and collaborative robots.
- Series: KY96 robot joint motor

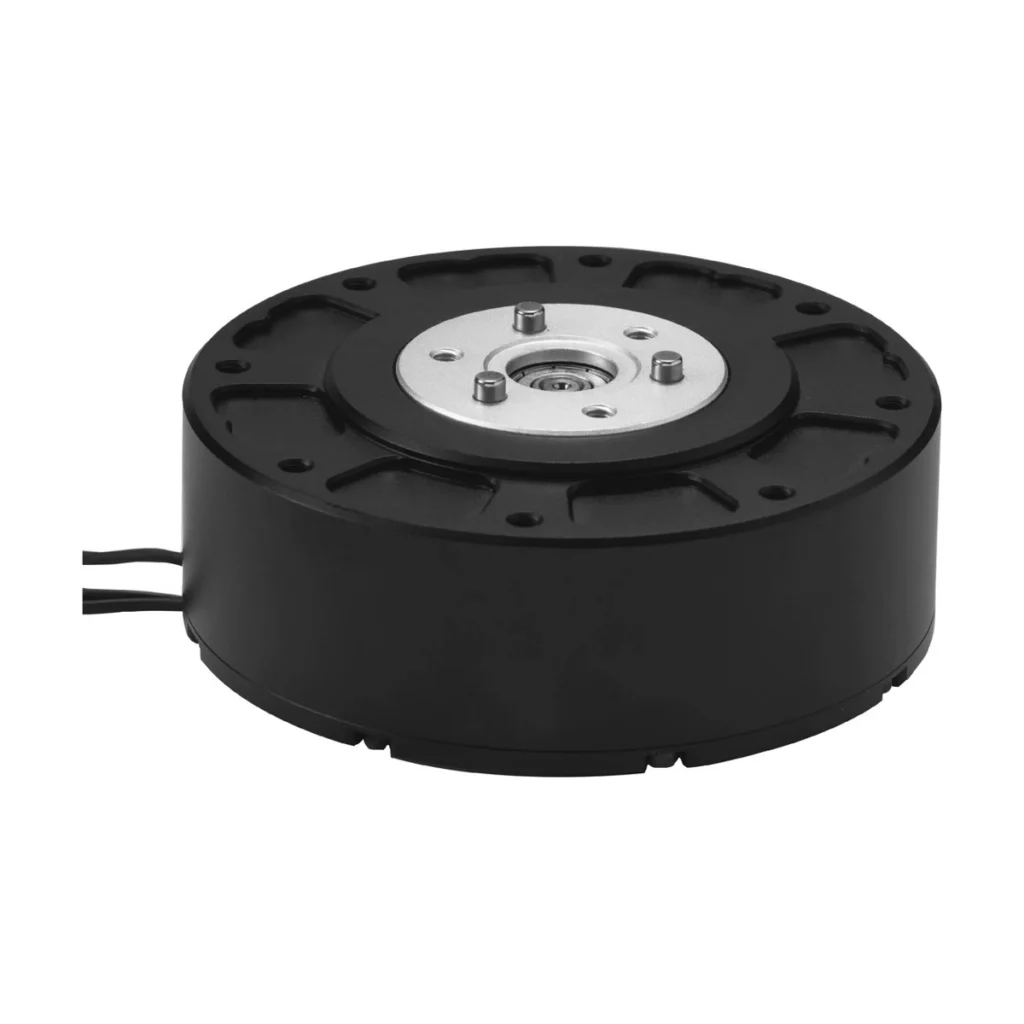
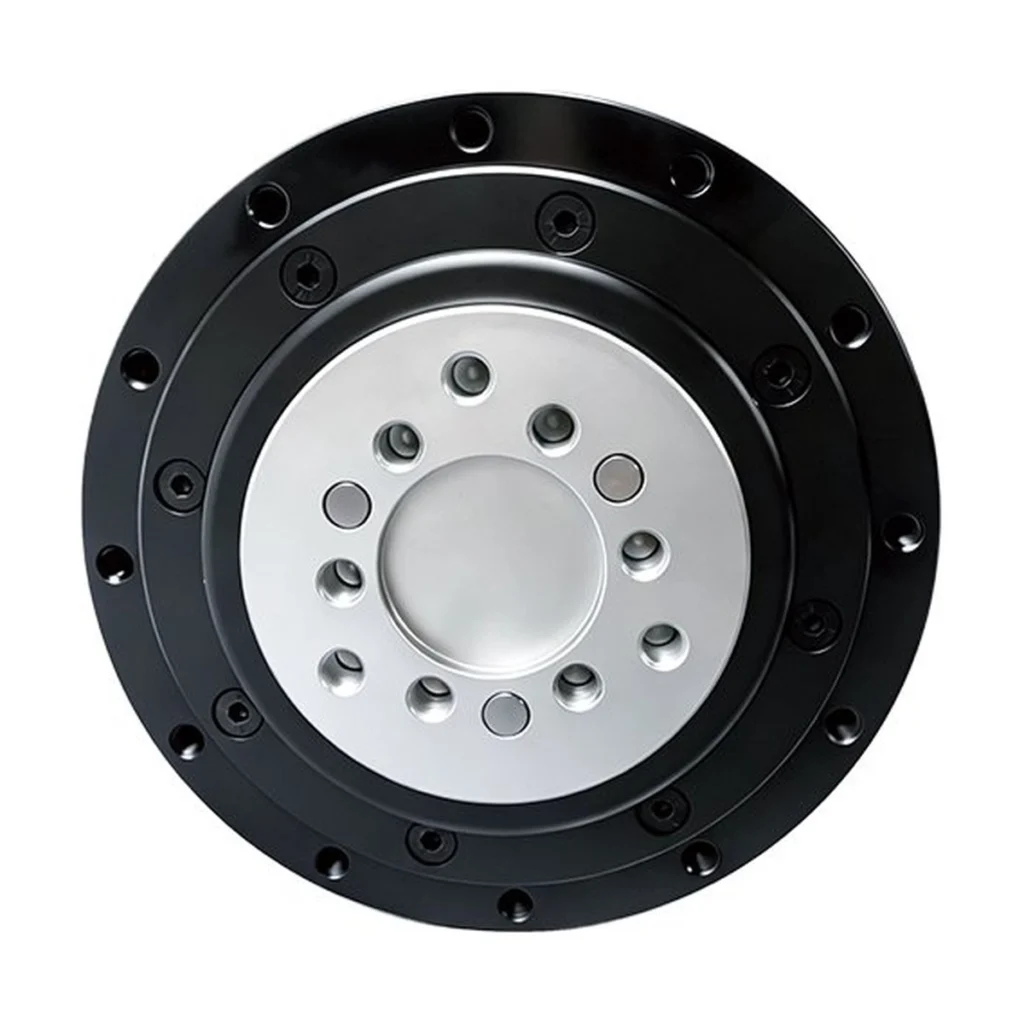
The Keya KY96BL04035-15 is a quasi-direct-drive robot joint with the motor, a 9:1 cycloidal reducer, the driver and dual encoders in one 48 V module: 15 N·m rated and 45 N·m peak torque, 170 rpm rated output speed.
Specifications and photos are the maker's published data. Datasheets are available on request.
Controlled over CAN 2.0 or CANopen in speed, torque, position or MIT mode. For humanoids, quadrupeds and collaborative robots.
Closest matches in this category, from any supplier.