3 kg rated, 5 kg peak payload.
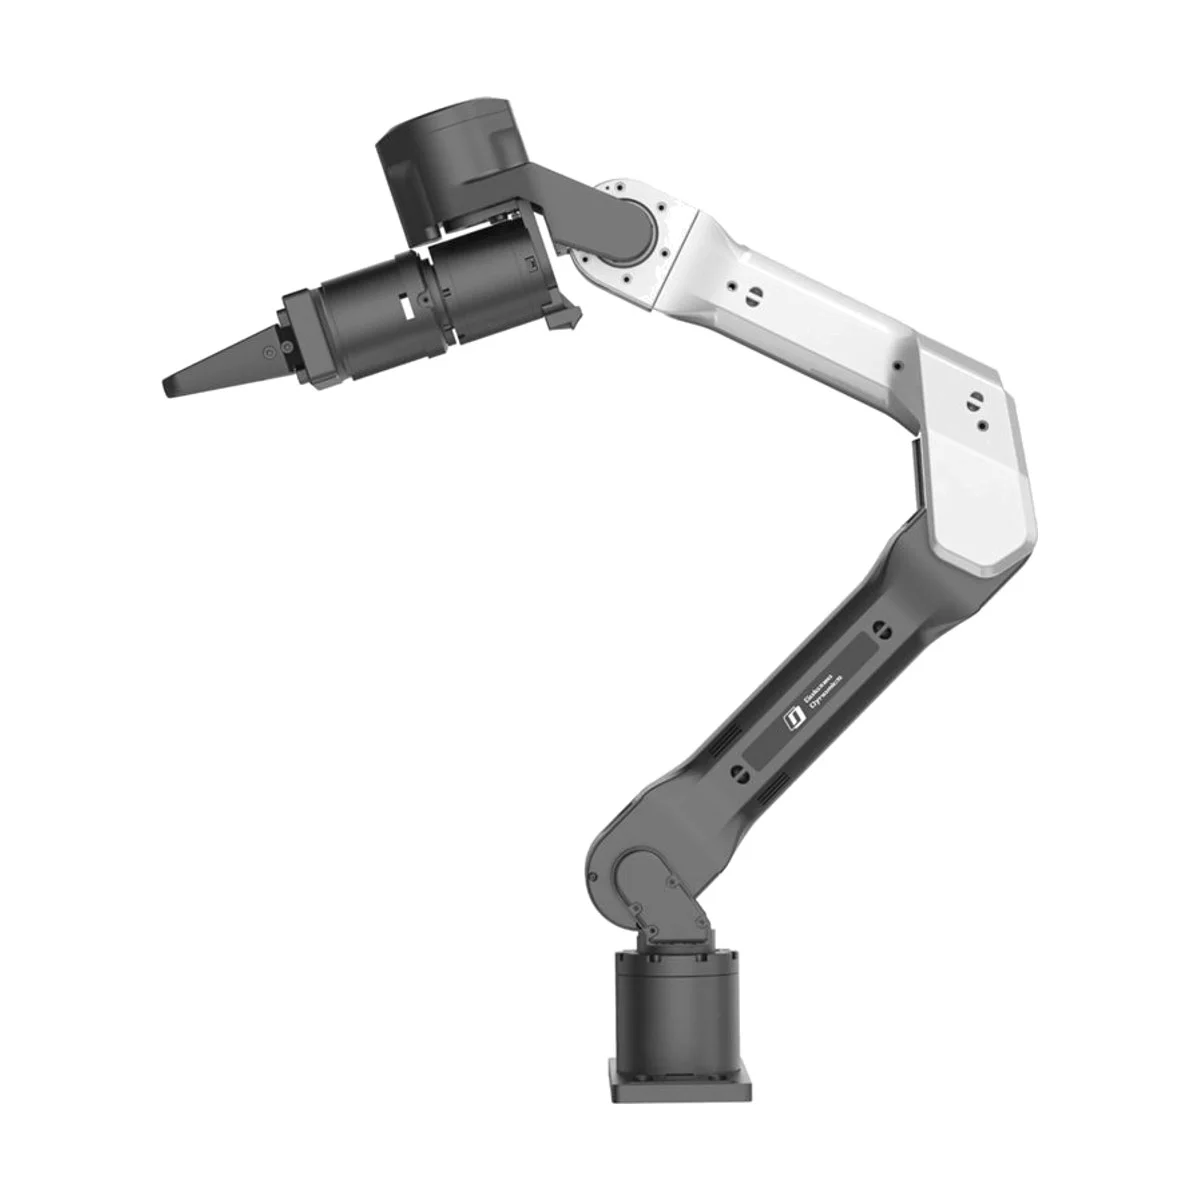
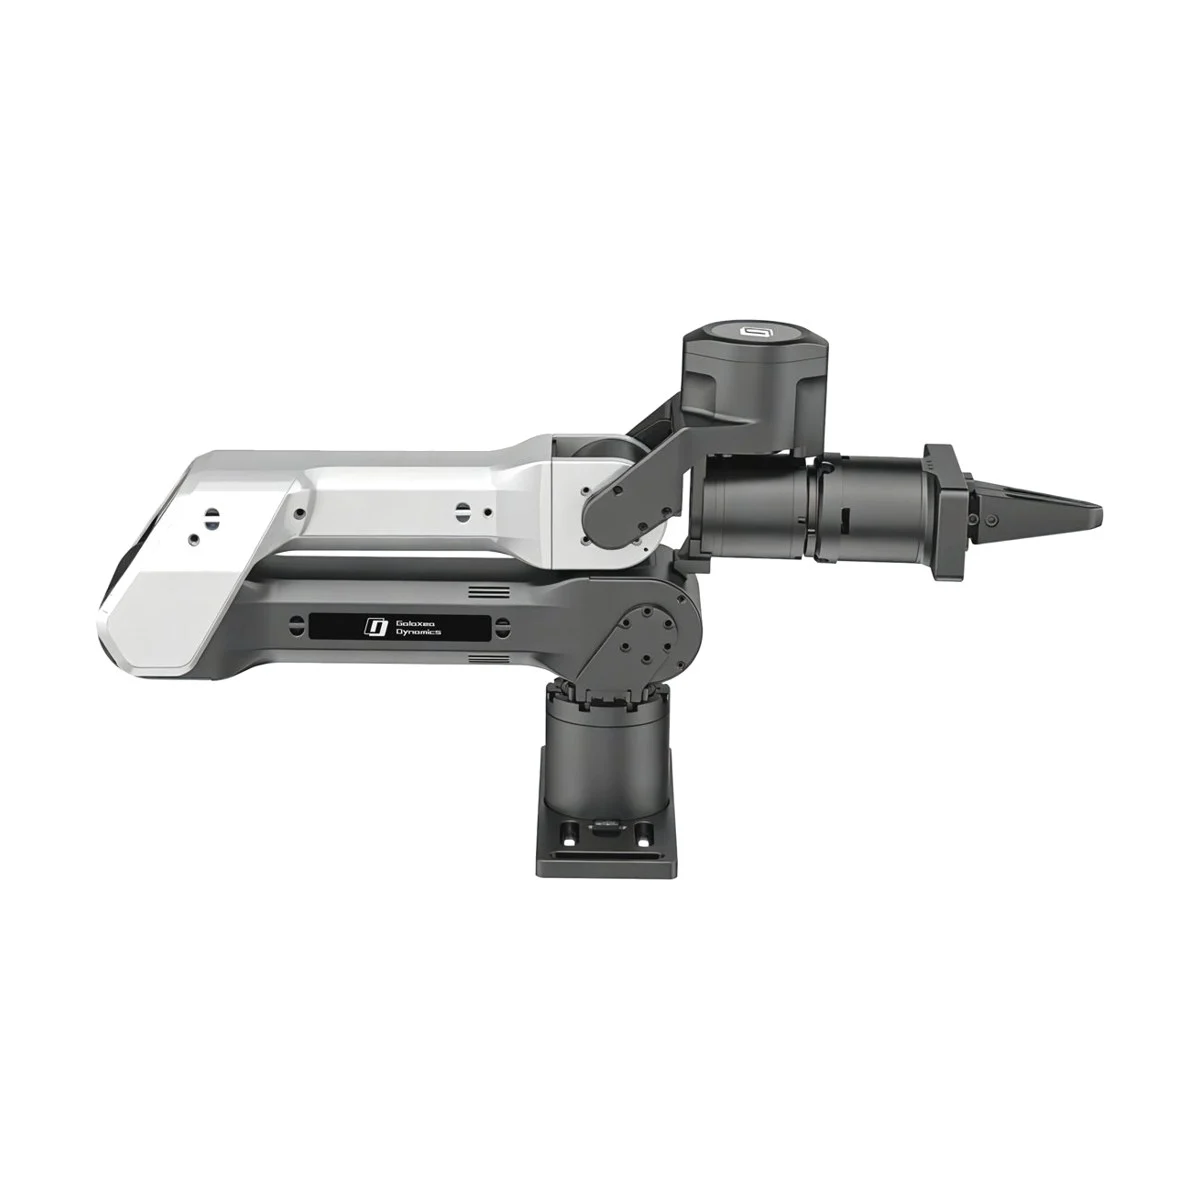

Galaxea LEMO A1Z Force-Controlled 6-DoF Robot Arm
$4,177.90
The Galaxea LEMO is a low-level research arm with built-in air cooling: no controller box, driven over CAN from a Linux PC, where the SDK solves the kinematics.
- Shipping
- Free on every order
- Duties and tariffs
- In the price, nothing extra at checkout
- Minimum order
- 1 unit
- Free shipping On every order.
- No tariffs at checkout Duties are in the price. Nothing to pay on delivery.
- US seller of record US invoices, terms and support.
- Maker's warranty Typically 12 months. Unused items can be returned within 30 days.
Research
Class
3 kg
Payload
6
Axes (degrees of freedom)
±0.1 mm
Repeatability
Estimated from motor current
Joint torque sensing
Specifications
Performance
- Class
- Research
- Payload
- 3 kg
- Axes (degrees of freedom)
- 6
- Repeatability
- ±0.1 mm
Mechanical
- Weight
- 5 kg
Integration
- Controller
- None: runs on your PC
- Cartesian control (built-in IK)
- On the host PC (SDK solves IK)
- SDK and interfaces
- Python SDK (Linux + SocketCAN, MIT force-position mode), marketed as 'AI-coding-native'
- Simulation
- URDF models bundled with SDK
- Joint torque sensing
- Estimated from motor current
- Grippers
- Galaxea G1Z Gripper ($500)
Specifications and photos are the maker's published data. Datasheets are available on request.
Made by
Galaxea
Typical applications
- Machine tending and lab automation
- Pick and place, kitting and test stations
- Robot learning and teleoperation data collection
- Education and research labs
- Mobile manipulators
Choosing the right one
- Size payload for the gripper, camera and part together, with margin: a 5 kg arm carrying a 1 kg gripper has 4 kg left.
- Rated payload holds at full reach. Most arms carry less when fully extended at full speed.
- Check that the controller takes Cartesian targets and solves the inverse kinematics itself; otherwise you write that math.
- Torque sensors in every joint make force control, collision detection and hand-guiding far better than current-based estimates.
- Try the vendor's simulator or URDF before you buy. A clean Python API and simulator are a good sign of the support you will get later.
- Hobby servo arms (under about $1,000) suit teaching and prototyping, not production duty cycles.
Related guides
About this product
Similar payload
Closest matches in this category, from any supplier.
-
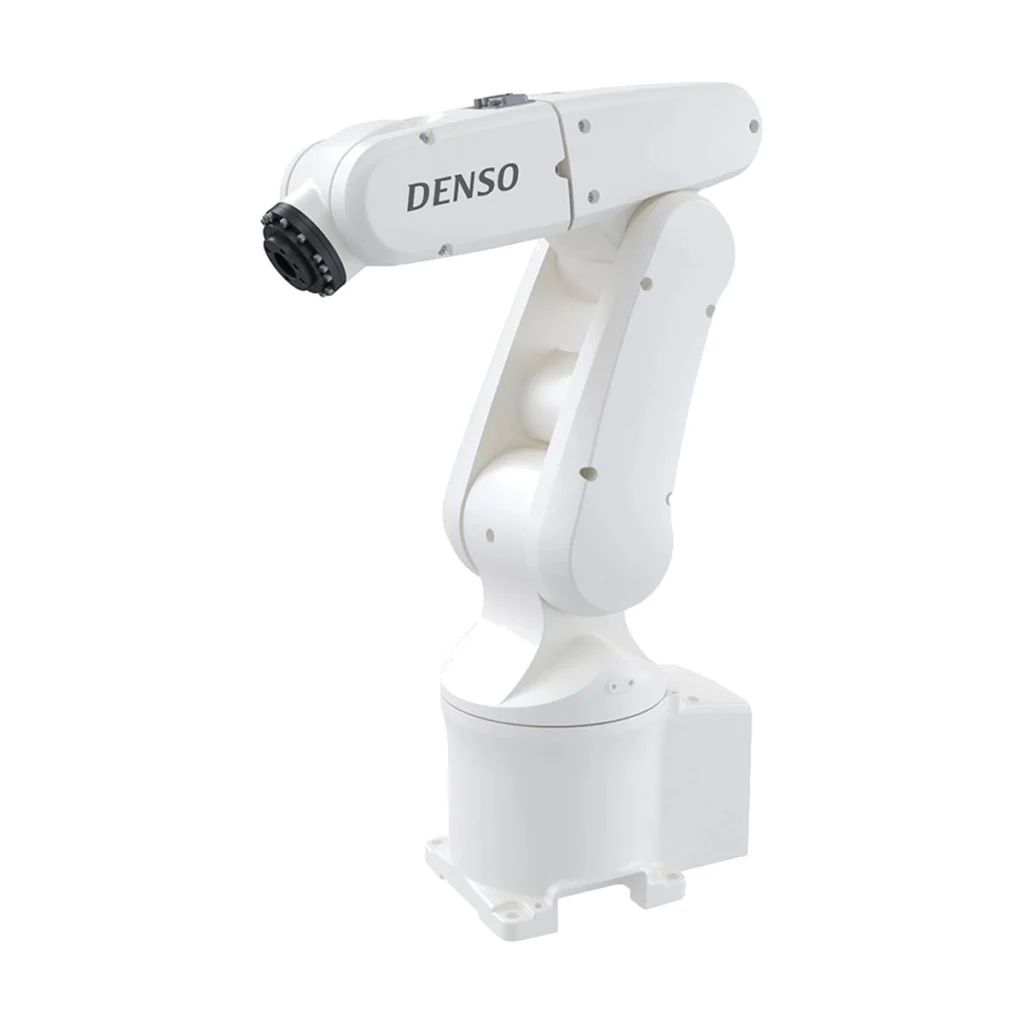
DENSO VP-5243 5-Axis Industrial Robot Arm
Industrial3 kg430 mmPrice on request -

DENSO LPH040A1 4-Axis SCARA Robot
Industrial3 kg400 mmPrice on request -

JAKA Zu 3 Collaborative Robot Arm
Collaborative3 kg626 mm$24,488.90 -
DENSO VP-6242 6-Axis Industrial Robot Arm
Industrial2.5 kg432 mmPrice on request